
1
Repos
200
Stars
29
Forks
3
Watchers
🏆 Show off this rank
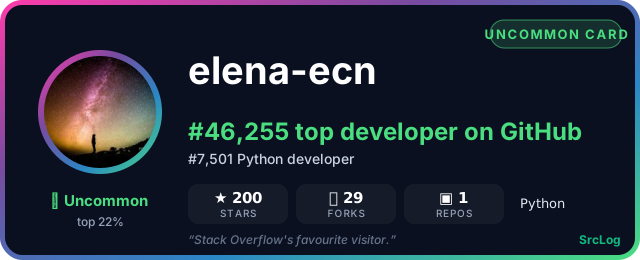


Add it to a GitHub README or profile — the card updates as the ranking changes: