
4
Repos
2.7k
Stars
549
Forks
54
Watchers
🏆 Show off this rank
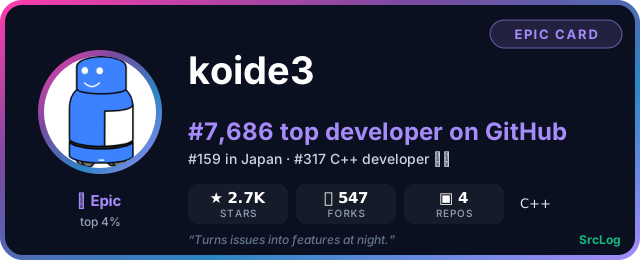

Add it to a GitHub README or profile — the card updates as the ranking changes:
Repositories (4)
small_gicp
koide3/small_gicp
C++
Efficient and parallel algorithms for point cloud registration [C++, Python]
1.1k
142
hdl_localization
koide3/hdl_localization
C++
Real-time 3D localization using a (velodyne) 3D LIDAR
1k
337
iridescence
koide3/iridescence
C++
Visualization library for rapid prototyping of 3D algorithms [C++, Python]
543
68
pykalman_test
koide3/pykalman_test
Python
A simple UKF demo using pykalman
8
2